Yixuan Huang
I am Yixuan Huang, a Master of Science student in Robotics at the University of Michigan.
I am interested in robot learning for manipulation and navigation: generative policies for long tasks, operation that stays safe and stable when it is repeated, and sim-to-real transfer to real hardware.
I got here by trying a lot of things: classical planning and multi-arm rearrangement, 3D reconstruction and sensing, deep learning, embedded and FPGA hardware, and distributed data systems.
I worked remotely with the Algorithmic Robotics and Control Lab at Rutgers University on planning and optimization for multi-arm tabletop rearrangement. I also worked as a Research Intern at the Shanghai Artificial Intelligence Research Institute (SAIRI), where I worked on plant information acquisition, RGB-D reconstruction, and 3D modeling for an agricultural robotics project.
I enjoy talking with people working on robot learning.
Go Blue!
News View All
- : Started the M.S. program in Robotics at the University of Michigan.
- : Admitted to the M.S. program in Robotics at the University of Michigan.
- : Chaired a joint online session on cloud computing between the Shanghai Artificial Intelligence Research Institute (SAIRI), Brazil's National Laboratory for Scientific Computing (LNCC), and the project's industry partners.
- : Joined the Shanghai Artificial Intelligence Research Institute (SAIRI) as a Research Intern, also affiliated with MindSpore Shanghai.
- : Joined the Algorithmic Robotics and Control Lab at Rutgers University as a Research Intern, working remotely.
- : Won the First Prize in the China Undergraduate Engineering Practice and Innovation Ability Competition.
Education


Wuhan University of Technology, Wuhan, China
School of Information Engineering
B.S. in Electronic Information Engineering
-
Outstanding Graduate, Class of 2026
Experience

Rutgers University, New Brunswick, NJ
Algorithmic Robotics and Control Lab
Research Intern, Remote
-
Advisor: Prof. Jingjin Yu
Focus: Multi-arm tabletop multi-object rearrangement planning and optimization

Shanghai Artificial Intelligence Research Institute, Shanghai, China
R&D Group
Research Intern, also affiliated with MindSpore Shanghai
-
Mentor: Dr. Tianrui Shen
Worked on a SAIRI-led agricultural robotics project involving plant information acquisition, RGB-D reconstruction, and 3D modeling.
Blog View All
Selected Projects View All
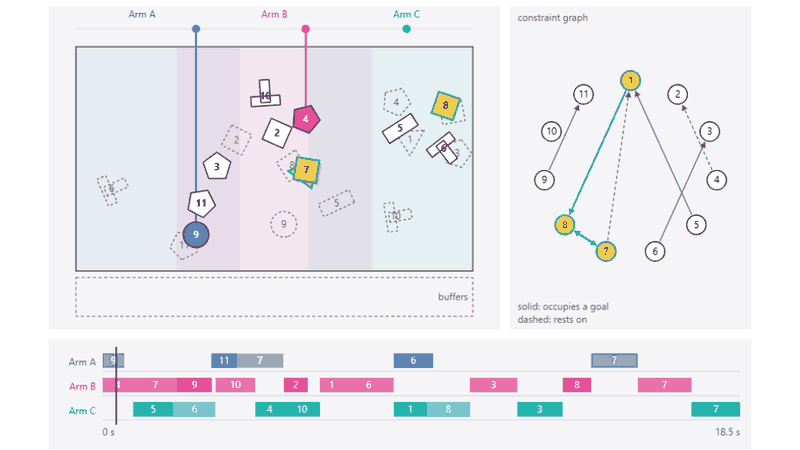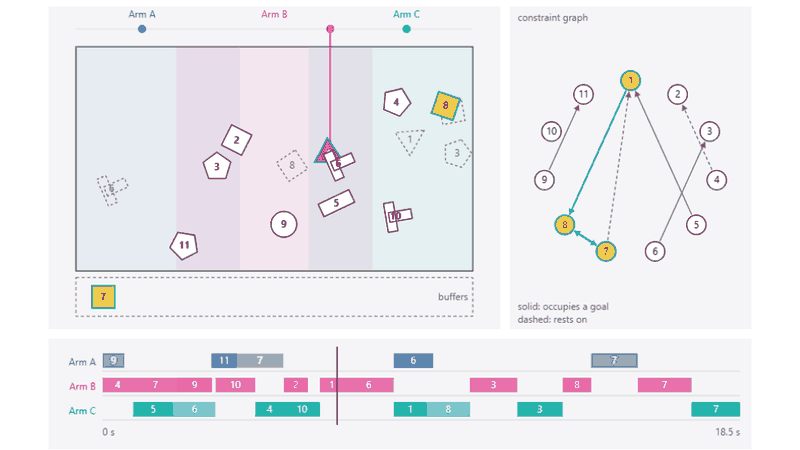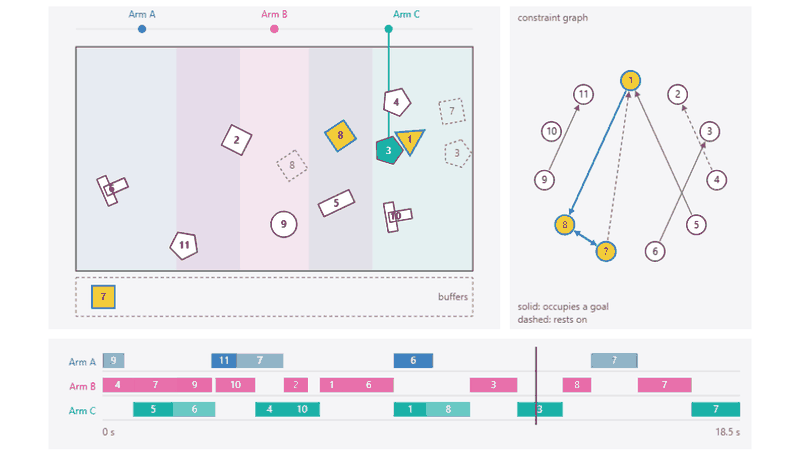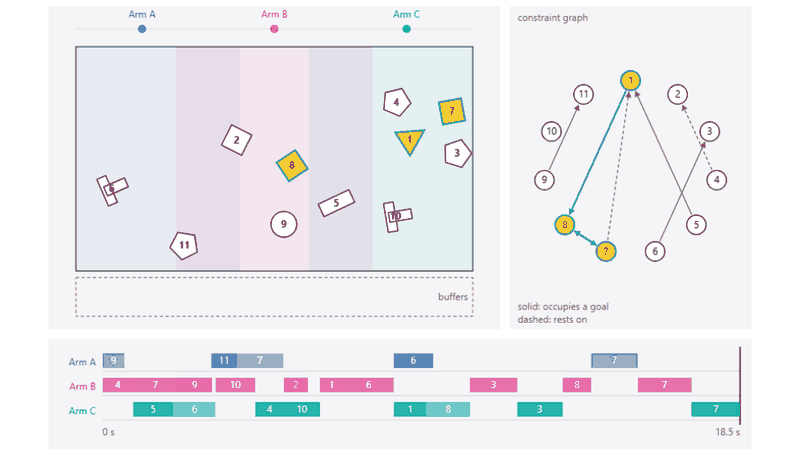
Multi-Arm Tabletop Multi-Object Rearrangement Planning and Optimization
Research with the Algorithmic Robotics and Control Lab at Rutgers. From a high-level problem posed by the advisor, I developed the formulation, the model, and the implementation for rearranging tabletop objects with several arms when goals may be occupied, with dependencies, buffer space, action count, execution time, and arm availability as explicit planning variables.
Role: Developed the formulation and the model, wrote the pseudocode and the implementation, explored algorithmic approaches, and produced a systematic set of simulation results.
Agricultural Robotics and 3D Reconstruction
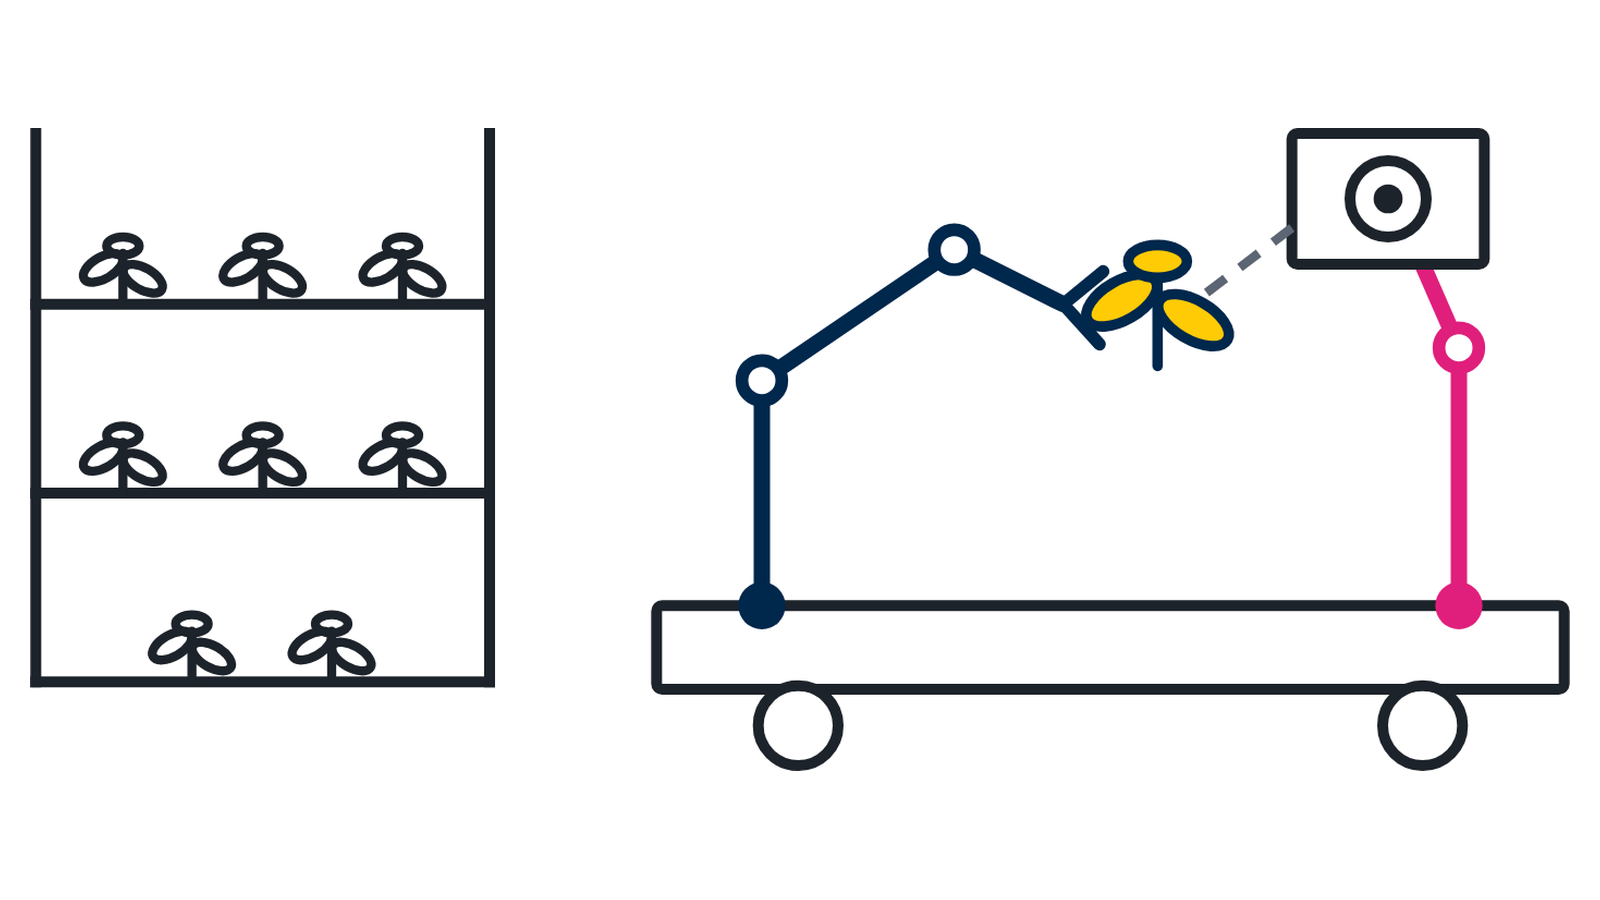
Research internship at the Shanghai Artificial Intelligence Research Institute, on a project run with the Shanghai Academy of Agricultural Sciences. I built the sensing chain for a controlled indoor growing facility: mobile platform and arm control, multi-view RGB-D acquisition, 3D reconstruction, and the leaf-area and root measurements taken from it.
Role: Built the robot-arm and mobile-platform control, the image acquisition, and the reconstruction pipeline; led the leaf-area and root measurement work with colleagues.
Honors & Awards
Beyond Academia Explore
Thanks for making it this far. I hope this website has given you a sense of my academic journey and the work I care about. I've also kept a few things here that are a little less academic and more personal.
Beyond Academia holds personal writing, photographs, hobbies, travel notes, and memories I want to keep. I explain why I made that space in Why I Keep a Space Beyond Academia.
Outside work, I enjoy guitar, tennis, table tennis, video games, traveling, and reading. They are ordinary parts of my life, but also meaningful ways for me to stay curious, connect with others, and find a little balance.